- AC Drives
- Industrial Communications
- PLC & I/O Cards
- Vibration Monitoring
- Automation Accessories
- Controllers & Data Acquisition
- CCTV & Security
- Encoders
- Industrial Computers
- Safety Switches & Guard Locking
- HMI Displays
- Motor Soft Starters
- Isolator & Barrier
- Pneumatic Cylinders
- Servo Drives
- Automation Software
- Robotics
- Machine Vision
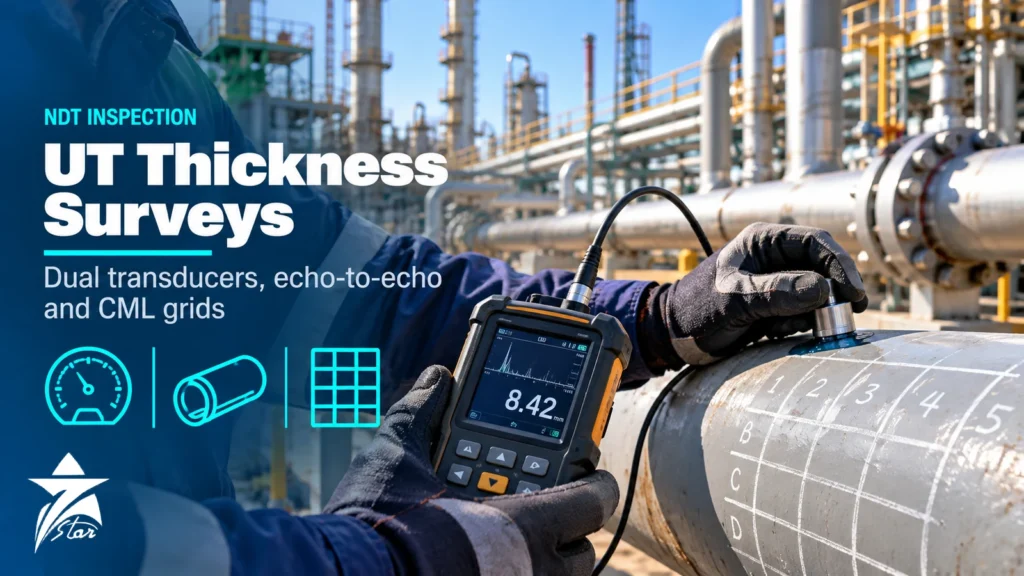
Ultrasonic thickness measurement is the backbone of every corrosion survey on piping, pressure vessels and storage tanks: it gives a remaining-wall number from one side of the steel, while the line stays in service. The difficulty is that a corrosion survey is only as good as its weakest reading. A wrong transducer, a coating that adds a millimetre to every value, a hot surface that shifts sound velocity or a grid that misses the deepest pit can make a corroded line look healthy, or trigger an unnecessary replacement. This guide explains how corrosion gauges work, how to choose transducers, when to use echo-to-echo readings through paint, how to set up grid surveys at condition monitoring locations, and how to turn readings into corrosion rate and remaining life.
How an Ultrasonic Corrosion Gauge Measures Wall Thickness
The gauge sends a short ultrasonic pulse into the wall and times the echo returning from the far surface (the back wall). Thickness is half the round-trip time multiplied by the longitudinal sound velocity of the material. For carbon steel the velocity is close to 5,900 m/s, so a time error of only a few nanoseconds becomes a measurable thickness error. That is why velocity, zero offset and probe delay must be set correctly before any survey reading counts.
Corrosion gauges differ from precision gauges in one important way. A precision thickness gauge is designed for smooth, parallel surfaces such as machined parts, plastics or thin sheet, and usually uses single-element contact or delay-line probes. A corrosion thickness gauge is optimised for rough, pitted, scaled and coated surfaces and almost always uses dual-element transducers, because the target is the minimum remaining wall, not the average.
Dual-Element Transducers: Why They Dominate Corrosion Work
A dual-element transducer has separate transmitting and receiving crystals mounted on delay lines and tilted slightly towards each other. The crossed beams create a focal zone below the surface, which improves sensitivity to the rounded bottoms of pits and suppresses the large surface echo that would otherwise mask near-surface readings. The price of that geometry is a V-shaped sound path, so the gauge applies a V-path correction, usually recalled automatically when it recognises the probe.
Selection of ultrasonic transducers for corrosion surveys follows a few practical rules:
- Frequency: 5 MHz duals are the general-purpose choice for carbon steel piping and vessels. Lower frequencies (around 2 MHz) penetrate thick, coarse-grained or heavily scaled walls better; higher frequencies (7.5–10 MHz) resolve thinner walls.
- Contact face: small tip diameters fit small-bore pipe and tight curvature; larger faces couple better on flat plate and tank shells.
- Temperature rating: standard duals are intended for near-ambient surfaces. High-temperature duals with suitable couplant can take brief contact on much hotter surfaces, but contact time and cool-down intervals given by the manufacturer must be respected.
- Cable and connector: match the connector type and the gauge’s probe recognition; a non-recognised probe needs a manual V-path calibration.
- Wear: dual delay lines wear on rough steel. A worn face changes the zero and can tilt readings; check it against a reference block at the start of every shift.
Ultrasonic Thickness Measurement Modes Compared
Most modern corrosion gauges offer several modes. The right one depends on whether the surface is bare or coated, and whether you are hunting pits or confirming general wall loss.
| Mode | What is timed | Best use | Limitations |
|---|---|---|---|
| Pulse-echo (dual) | Excitation to first back-wall echo, corrected for V-path | Bare or blasted steel, pitting surveys, minimum wall | Coating thickness is added to the reading, multiplied by the velocity ratio |
| Echo-to-echo | Interval between two successive back-wall echoes | Painted or coated steel in good condition | Needs at least two clean back-wall echoes; heavily pitted walls may not produce them |
| Multiple-echo (three echoes) | Several consecutive back-wall intervals, cross-checked | Coated plate and pipe where reading confidence matters | Same echo requirement, narrower thickness range |
| Through-coating (manufacturer-specific) | Metal and coating separated using one back-wall echo | Coated walls where multiple echoes are not available | Needs the specific probe; check coating range in the datasheet |
| A-scan / B-scan display | Waveform or cross-section along a scan line | Verifying doubtful readings, mapping pitted areas | Requires trained interpretation |
Echo-to-Echo Readings Through Coatings
Coatings slow sound down. Epoxy and similar paint systems have longitudinal velocities well below half that of steel, so a gauge calibrated for steel and used in plain pulse-echo mode reads a coating as roughly two to two-and-a-half times its real thickness. A 0.5 mm paint system can therefore add more than a millimetre to every value. On a 6 mm line with a 4.8 mm retirement thickness, that error alone can hide a reportable finding.
Echo-to-echo mode solves this by ignoring the first echo (which includes the coating path) and timing only the interval between back-wall echoes that both travel inside the metal. Because the coating contribution is identical for each echo, it cancels. Three practical points decide whether echo-to-echo will work on the day:
- The coating must be well bonded. Disbonded or blistered paint blocks sound and produces no reading at all.
- The back wall must be smooth enough to return at least two clean echoes. Severe internal pitting scatters the second echo, which is exactly when the reading matters most.
- Gate and gain settings must be checked on an A-scan for the first readings of the survey, to make sure the gauge is not locking onto a coating echo or a mode-converted signal.
Where echo-to-echo cannot hold a reading, remove the coating locally at the test point, take a pulse-echo reading on bare steel and record the coating removal so it is repaired. Do not mix coated and bare readings at the same location between surveys without noting it; the apparent corrosion rate will jump or fall for no physical reason.
Calibration and Setup Before the Survey
Calibration is done on the same material, at a similar temperature, over the thickness range of interest. A two-point calibration on a step block bracketing the expected readings, one step near the thinnest expected value and one near nominal, sets both velocity and zero. Standard steel step blocks and reference blocks are available as calibration blocks in carbon steel, stainless and other alloys.
- Perform a probe zero (or automatic zero) whenever the transducer is changed or has warmed up.
- Verify on a known thickness at the start, at intervals during the survey and at the end; record the check values in the survey file.
- For alloys other than carbon steel, measure the velocity on a sample of known thickness rather than relying on a handbook value.
- Use the same couplant type throughout; thick gel on rough surfaces, high-temperature couplant on hot lines.
Designing Grid Surveys at Condition Monitoring Locations
Inspection codes for in-service equipment, such as API 570 for piping and API 510 for pressure vessels, use the term condition monitoring location (CML) for the defined areas where periodic thickness readings are taken. The value of a corrosion survey comes from repeating readings at exactly the same points, so the survey design is more important than the gauge model.
Choosing CMLs
- Areas of expected accelerated attack: elbows and tees (outer radius on erosive service), downstream of control valves and orifices, injection and mix points, dead legs and low points where water settles.
- Representative straight runs to establish general corrosion rate for each circuit.
- Areas with known history: previous minimum readings, repairs, clamps and sleeves.
Laying Out the Grid
On pipe, readings are usually taken at four quadrants (12, 3, 6 and 9 o’clock) at each CML, with additional points on elbows. On vessels and tank shells a rectangular grid is marked and numbered. The grid spacing is a judgement call: a coarse grid shows general wall loss, but localised pitting can sit between grid points. Where pitting is suspected, take a spot reading at the grid point and also scan the surrounding area for the minimum value, recording both. Permanent marking (paint stencils, engraved tags or drawings with photographs) ensures the next inspector reads the same spot.
Gauges with data loggers allow grid files to be prepared in advance with circuit, CML and point identifiers. That avoids transcription errors and makes trend analysis possible directly from the exported file.
From Readings to Corrosion Rate and Remaining Life
The engineering output of a survey is not a list of thicknesses but a corrosion rate and a remaining life for each CML. The commonly used relationships are:
- Corrosion rate = (previous thickness − current thickness) ÷ years between readings. Long-term rate uses the initial or baseline thickness; short-term rate uses the two most recent surveys.
- Remaining life = (current thickness − required thickness) ÷ corrosion rate, where required thickness comes from pressure design plus structural minimums.
- Next inspection date is then set from remaining life under the rules of the applicable inspection code and the owner’s risk-based inspection programme.
Readings that suggest metal growth (a later reading thicker than an earlier one) are a sign of measurement error, not corrosion reversing. Investigate the CML location, the mode used and the calibration before the value goes into the trend.
Common Mistakes That Corrupt Corrosion Data
- Measuring through paint in pulse-echo mode and comparing the result with a bare-steel baseline.
- Reading a lamination or hydrogen-induced crack as wall loss. A mid-wall reflector gives a sudden thin reading over a wide area with a clean back wall elsewhere; confirm with an A-scan on a flaw detector before declaring a thin spot.
- Doubling on thin walls: below the lower range of the probe, the gauge can lock on the second echo and display about twice the real thickness.
- Ignoring temperature. Sound velocity in steel falls as temperature rises, so readings on hot lines read slightly thick unless corrected, and a hot transducer drifts.
- Pressing too hard on curved surfaces or rocking the probe, which produces unstable or low readings.
- Taking readings at a different spot each survey, which turns positional variation into an apparent corrosion rate.
Field Conditions in Oman and the GCC
Gulf conditions affect both the equipment and the data. Pipe racks exposed to summer sun can reach surface temperatures far above the 50 °C air temperature, so couplant evaporates quickly and standard probes heat up; schedule surveys in the early morning or use high-temperature probes and couplant. Fine dust gets between the probe face and the steel and causes erratic readings, so clean each point before coupling. Coastal plants, desalination intakes and seawater cooling systems combine external chloride attack with internal pitting, which is where dual-element pitting surveys and echo-to-echo readings on coated lines are both needed. In sour service, mid-wall reflections from hydrogen-induced cracking must be separated from genuine wall loss. Finally, where surveys are carried out in classified hazardous areas, check that the gauge and battery arrangement meets the site’s permit requirements.
Maintenance and Troubleshooting
- No reading or flashing value: check couplant, surface preparation, probe cable and the gauge gain; try a lower-frequency dual on rough or thick walls.
- Readings jump between two values: often doubling or a coating echo; view the A-scan and adjust gain or blanking.
- Drift during the day: worn or hot probe face; re-zero and recheck against the reference block.
- Cable faults: intermittent readings when the cable is flexed usually mean a damaged cable; spare cables are a low-cost item worth carrying.
- Data integrity: back up logger files after each shift and keep calibration certificates for the gauge and the reference blocks with the survey records.
Ultrasonic Thickness Measurement Survey Checklist
- Inspection plan with circuit drawings, CML locations and previous readings available.
- Corrosion gauge with V-path correction, echo-to-echo capability for coated lines and A-scan display.
- Dual-element probes in suitable frequency, tip size and temperature rating, plus a spare.
- Step block of the same material bracketing expected thickness; verification at start, during and end.
- Couplant suitable for surface temperature; cleaning tools for dust and loose scale.
- Grid file loaded in the logger and CML marking materials on hand.
- Procedure for separating laminations or cracking from wall loss.
- Corrosion rate and remaining life calculated and reviewed by the inspection engineer after the survey.
Sourcing Ultrasonic Thickness Gauges Through Seven Star LLC
Seven Star LLC supplies corrosion and precision thickness gauges, dual-element and high-temperature transducers, cables, couplants and calibration blocks on request for plants in Oman and across the GCC. We can help with selection, cross-checking probe and connector compatibility with your existing gauges, and confirming part numbers against the manufacturer’s literature. Availability and lead time are confirmed at quotation.
\nPlanning a corrosion survey or replacing a worn probe? Send us the gauge model, the transducer part number or a photo of the nameplate, the thickness range and surface temperature, and we will return a quotation for the right gauge, probes and reference blocks.
Thickness Gauges We Supply
\n\n\n\nFor corrosion surveys with dual-element transducers, Seven Star LLC supplies the Waygate DM5E thickness gauge and the Evident 39DL PLUS ultrasonic thickness gauge; for precision single-element work there is the Evident 72DL PLUS. Coating thickness on the same assets can be checked with the Elcometer 415 or Elcometer 355. Flaw detection beyond thickness is handled by the Waygate Krautkramer USM 36. Ask for a quote with your probe and material requirements.
\nFrequently asked questions
Can an ultrasonic thickness gauge measure through paint?
Yes, if it has an echo-to-echo, multiple-echo or manufacturer-specific through-coating mode. In plain pulse-echo mode the coating is added to the reading and, because sound travels much more slowly in paint than in steel, it appears roughly two to two-and-a-half times thicker than it really is.
Why do corrosion gauges use dual-element transducers?
Dual-element probes separate the transmitting and receiving crystals, which removes the large surface echo and creates a focal zone under the surface. This makes them more sensitive to the rounded bottoms of pits and better at finding the minimum remaining wall on rough, corroded steel.
What frequency transducer should I use for pipe corrosion surveys?
A 5 MHz dual is the usual general-purpose choice for carbon steel piping and vessels. Use around 2 MHz for thick, hot or heavily scaled walls and 7.5–10 MHz for thin sections where resolution matters more than penetration.
How do I calculate corrosion rate from thickness readings?
Corrosion rate is the loss in thickness between two surveys divided by the years between them. Remaining life is then the current thickness minus the required thickness, divided by that rate, and the next inspection interval is set under the applicable inspection code.
Why does my gauge sometimes show double the real thickness?
On thin walls near or below the probe's lower limit, the gauge can trigger on the second back-wall echo instead of the first and display roughly twice the true value. Checking the A-scan, adjusting gain or using a higher-frequency probe resolves it.
Can a thickness gauge tell the difference between corrosion and a lamination?
Not reliably from a single digital value. A lamination or hydrogen-induced crack reflects sound from mid-wall and looks like a sudden thin reading; an A-scan on a flaw detector or a gauge with waveform display is needed to confirm whether the wall is actually lost.
Was this guide helpful?One click helps us write better guides for engineers.
Thank you! Glad it helped. Need this equipment for your project? Request a quotation
Thank you. We will use this to improve the guide.